Monday, February 19, 2007

Ice Accident

Hi there,

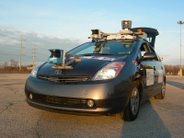
I've got some bad news. Ben will be out of service for a little while. While we were getting Ben setup in front of the Levine loading dock, a large bunch of ice fell off the roof of Fisher Bennett and smashed our windshield, hood, and right mirror. The ladar's were on the roof and one took enough of a hit to knock it cockeyed on it's mount, but it tested ok in the lab afterwards.

The only major problem with Ben is the windshield, it's pretty opaque and obviously compromised. The mirror needs to be replaced. And the hood is cosmetic, but probably a good thing to fix so we don't look like we got into an accident. All other systems are fine.

In the good news. None of us were hurt. As the first smaller stuff came down we moved away. Also, we now successfully have tested LADAR producing elevation maps feeding directly into matlab and then feeding a map to the planner. We were on our way out to record some data to try planning through when the ice fell.

Here are some pictures:


Tully

Friday, February 16, 2007

(Great) Testing Results Featured in the Philadelphia Inquirer

We had a really fantastic testing day today - the steering control is now really good and very smooth (no jerking steering wheel etc - it actually looks like a human is driving). We did have a reasonably persistent problem with the GPS jumping near the poles in the car park which is why we have some discrete jumps in the route traces - but this is something that we are investigating several different avenues to solve (new pose system, pose filter changes etc). Hence we got a lot of recorded data using benracer.dangerous (keyboard arrow control of the vehicle controls - great fun) of human driving and throttle/brake characterisation data so we should be able to build a good map of the throttle-brake characteristics to use in a new longitudinal controller.

The Philadelphia Inquirer reporter and photographer met us took photos of Ben and we took the reporter for a spin in the driving seat (with Ben driving) which he seemed to enjoy - read more about it and watch a video of the car here:
http://www.philly.com/mld/inquirer/16709897.htm


However - we also had a minor problem:
We smelt burning plastic in the car and stopped immediately - when we looked in the boot (trunk) we found that we had melted (the casing) *and* fried the wires connecting the 400V inverter to the 12V power supplied from the vehicle.

Alex

Thursday, January 18, 2007

Another Day in The Field

On Sunday we tested a new trajectory follower which is based on a value-function. The pose estimator was tested integrating all sensors including GPS, IMU, and car odametery.
The video production team is working on a promotion video of little ben performing an autonomous run which will display our GUI to the brains of the car.

Friday, January 5, 2007

Driving by the RNDF

Jim, Alex K., Heeten and I went to the Boeing lot with the Prius for
the first time on Sunday. Our objective was mainly to get acquainted
with the site, but we also took the opportunity to do some more
testing of the trajectory-following code and a simple RNDF. We
enabled the
trajectory follower's throttle control for the first time, since we weren't
willing to risk it in the smaller lot. Everything was pretty successful,
though the controller gains still need a lot of tuning. We were able
to follow some pretty interesting trajectories, including one based on
an RNDF we also built for the site.

Saturday, December 9, 2006

Ben Drives Himself!

This afternoon/evening we took Ben out to the small road behind the USPS parking lots and managed to fix the few remaining issues with drivers and we successfully demonstrated trajectory following with Ben, following (steering control only due to the confined space) straight and curved trajectories previously driven by Tully and recorded/played back via Sheep. Attached is the proof - the results were very encouraging the performance in terms of tracking is really quite good considering that there is still a reasonably significant amount of noise in the pose estimate which affects both the recording of the trajectory and the following (we are still occasionally bermuda triangulated to somewhere in manhattan momentarily). What is also impressive is that the controller that we tested is unchanged from the version that gives near equivalent performance in simulation - no gains were modified.

Alex

Robot Vehicle Driving Test

Little Ben - The Ben Franklin Racing Team vehicle, performing a autonomous control over the vehicle and follows a path demonstrated by an human driver.
First, the path demonstrated by manual driving is recorded. In the following section Little Ben is generating steering and throttle commands based on its perceived location and heading as given by the GPS locator.