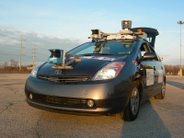
Sorry for the long delay in posting. We've been working hard on the vehicle and have made good progress.
Today we completed our official site visit. We successfully completed all 4 missions in approximately two hours and had time for a few extra demonstrations.
Photos are below. And hopefully we'll have a video to post soon as well.
Thank you to all our fans who came out to support us on this hot Sunday.
Sunday, July 8, 2007

Friday, May 25, 2007
New Photos Posted
There are new photos of the latest generation of sensor roof rack as well as new photos of the EMC system and computing rack.
Monday, May 21, 2007
Testing Update,
We made it up to Lehigh by midday and had a good afternoon of testing.
Tully
- We successfully logged performance data for trajfollower.
- We also drove the site visit course again now with OmniStar DGPS coverage.
- I successfully tested the distributed logging on the RT3K module, however the combination of Xforwarding, rendering, and NFS caused problems with the velodyne logging in this manner. So we logged in the old format as we drove with other vehicles around the site visit route.
- Dan demonstrated successful following using the matlab controller up to 17 mph forward and 15 mph in reverse in a relatively tight course.The vehicle was programmed to automatically slow for corners.
- And we were able to successfully navigate the site visit course with dense waypoints, with the problem that the tracks would drift off the road due to GPS offset.
Tully
Friday, May 11, 2007
DARPA Site Visit
"The Ben Franklin Racing Team has been selected to receive a site visit by DARPA officials in June 2007 ... "
Dr. Tony Tether, Director of the Advanced Research Projects Agency.
Tuesday, April 24, 2007
Intersection Navigation Demonstrated
Good news,
We successfully demonstrated intersection navigation to the level required for the site visit today. Drew videotaped our driving through an intersection after waiting for a car to clear a few times.
Also John and his students have laid down the centerline marking tape around the whole course and have made good looking stop lines for the intersection.
We have driven around the course 3 times with Little Ben to get out best estimate of it's position. This will be used to finalize our RNDF to submit this week.
Also of note we have new photos of the team up from last week.
Saturday, April 14, 2007
Video Submission Completed
Monday, April 9, 2007
Getting the Velodyne to work
We spent the day working on demonstrating intersection navigation including vehicle avoidance. We were able to demonstrate intersection navigation with empty obstacle maps. However we ran into technical difficulties when trying to translate the maps generated by the velodyne to the
planner.
Paul has helped me out and the Velodyne can render beautiful point clouds in real time. Now that we have the correct calibration for our unit we can watch people walk down the sidewalk from 20m away, and see 5+ cars around a busy intersection. Hopefully we can post some of the recorded data into videos soon.
Tully
Subscribe to:
Posts (Atom)